
4.3 桌面端启动 teleoperate
桌面端遥操作
启动遥操作
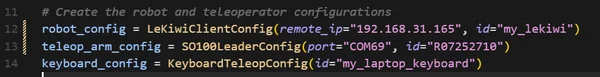
在主控电脑上修改遥操作脚本配置 examples/lekiwi/teleoperate.py,其中 remote_ip 为树莓派的 IP 地址,port 为 Leader 臂驱动板的端口号,id 为之前标定参数的 ID。(本地调试则 remote_ip="127.0.0.1")
conda activate lerobot
python examples/lekiwi/teleoperate.py
连接成功后输出:
[INFO] Connected to remote robot at tcp://172.17.133.91:5555 and video stream at tcp://172.17.133.91:5556.
操控方式
| 输入 | 控制对象 | 说明 |
|---|---|---|
| Leader 臂 | Follower 臂 | 1:1 动作映射 |
| W / A / S / D | 底盘移动 | 前进 / 左移 / 后退 / 右移 |
| Z / X | 底盘旋转 | 左转 / 右转 |
| R / F | 速度调节 | 加速 / 减速 |
速度模式
| 模式 | 线速度(m/s) | 旋转速度(°/s) |
|---|---|---|
| Fast | 0.4 | 90 |
| Medium | 0.25 | 60 |
| Slow | 0.1 | 30 |
macOS 用户需要在 系统偏好设置 → 安全性与隐私 → 输入监控 中授权终端键盘访问权限。
桌面端遥操作
linux: python examples/lekiwi/teleoperate.py
macos: python examples/lekiwi/teleoperate.py
windows: python examples\lekiwi\teleoperate.py